Training data—not a proxy.
UMI-L produces clean, precisely synchronized demonstrations designed for direct use in real-robot training and evaluation workflows.
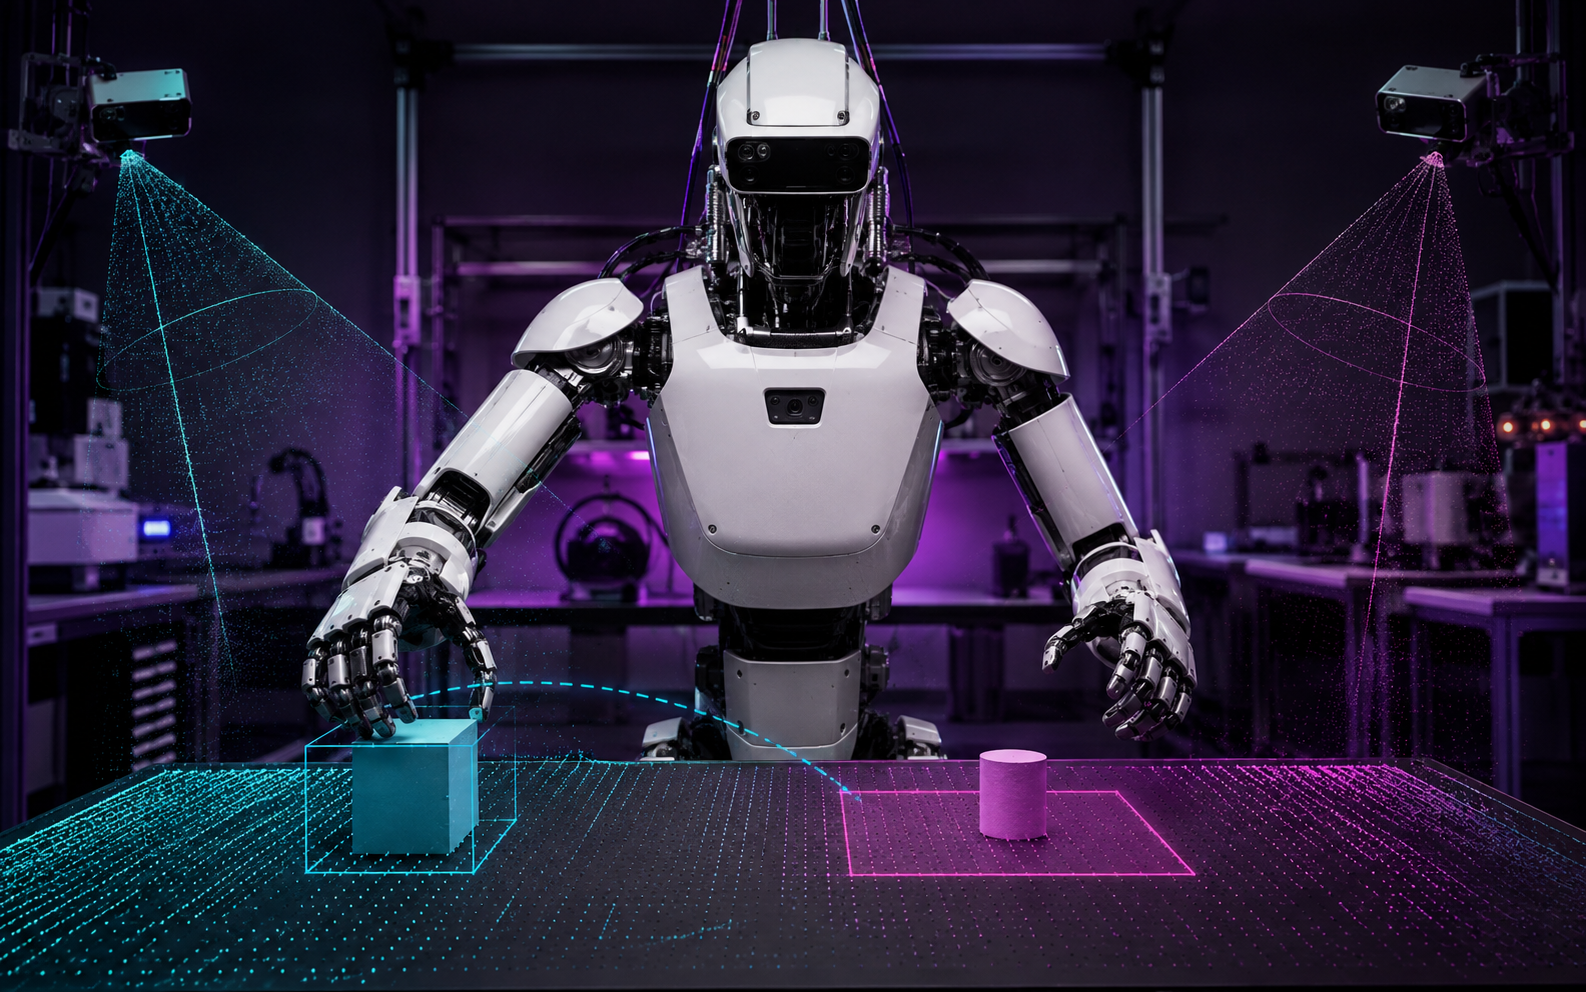
UMI-L is a complete data collection system for five-finger dexterous manipulation. It supports dexterous hands with up to 22 actively controlled degrees of freedom, with adaptable hardware and SDK support for additional dexterous hands and grippers. No robot platform is required.
REQUEST EARLY ACCESS ↗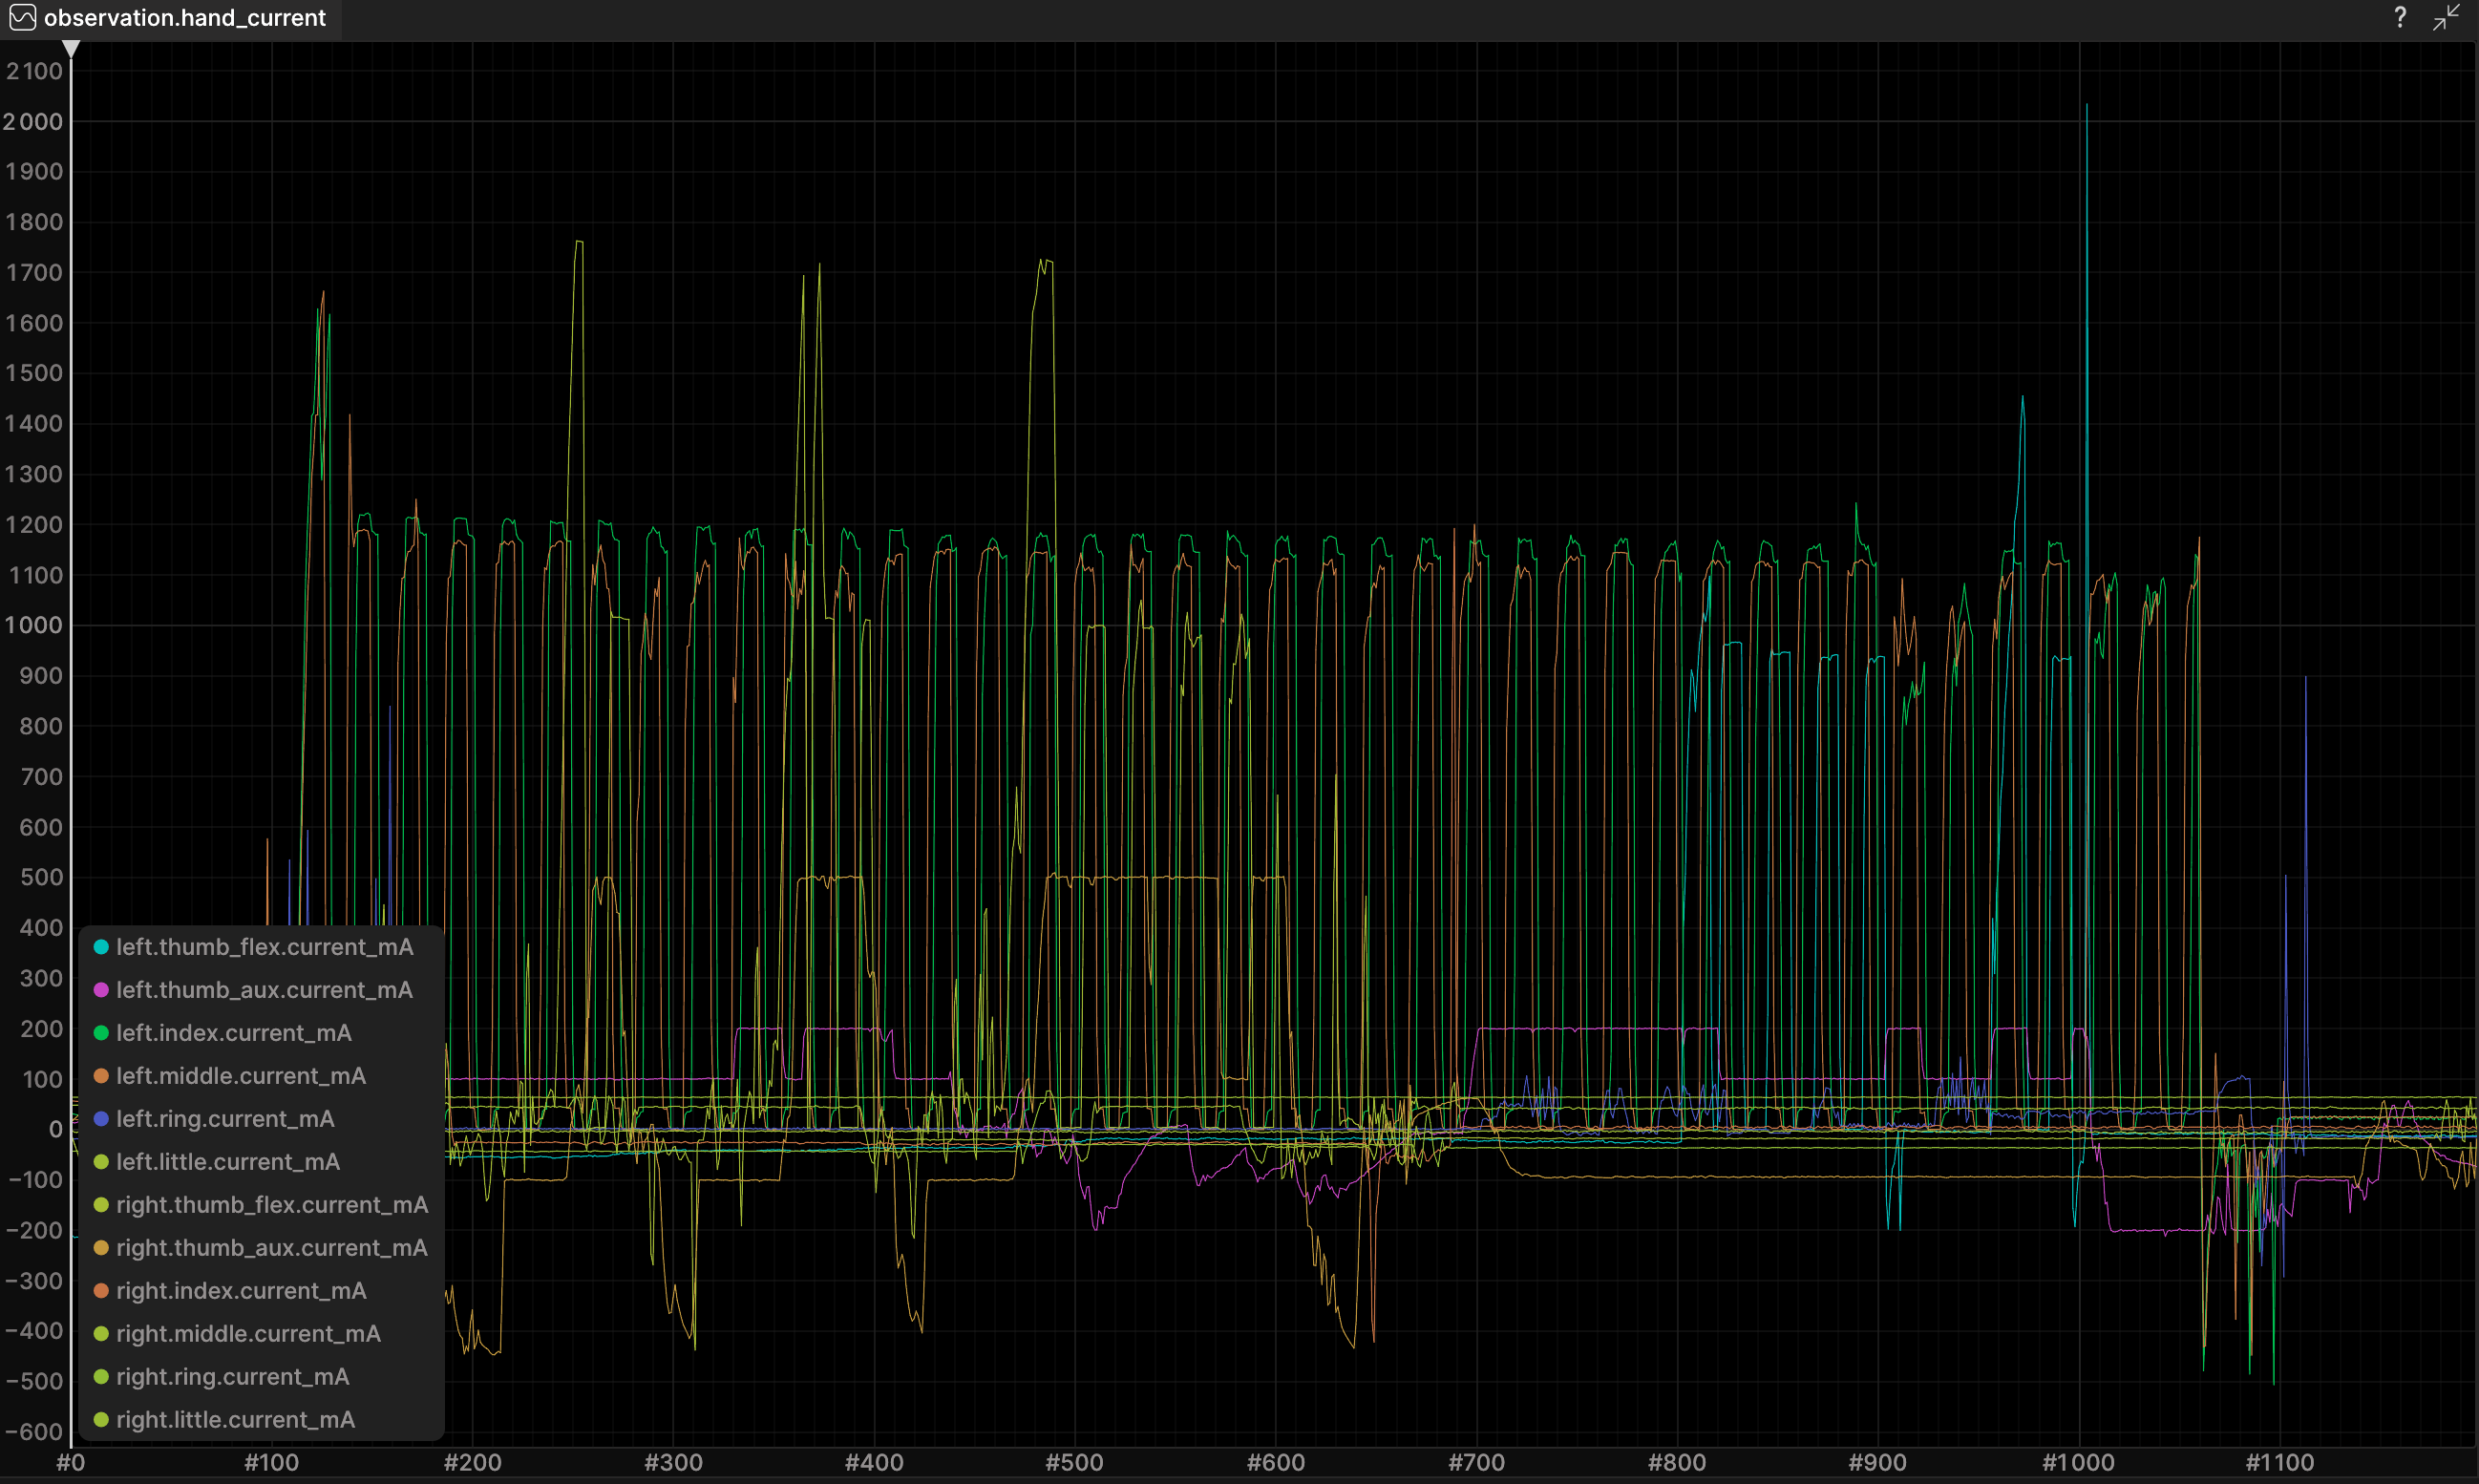
UMI-L produces clean, precisely synchronized demonstrations designed for direct use in real-robot training and evaluation workflows.
The operator controls the dexterous hand directly and feels real contact feedback, enabling natural in-the-wild collection without a robot body.
First-person video, bimanual spatial poses, dexterous-hand operation data, contact, and force-control signals are recorded on one timeline.
Low-cost pre- and post-processing supports multi-scene, coordinated five-finger datasets at scale. Deploying on the same hand platform reduces data adaptation and policy-transfer work.
RGB / DEPTHSTATE / ACTIONFORCE / TELEOP
VALID EPISODESALIGNED STREAMSTRACEABLE LINEAGE
KINEMATICSTRAJECTORIESSEMANTICS
VERSIONEDQUALITY-SCOREDMODEL-READY
83PROFILE INDEX
41UNCURATED
UNCURATED28
HOKFANG82
UNCURATED58
HOKFANG90
UNCURATED74
HOKFANG88
UNCURATED46
HOKFANG84
UNCURATED18
HOKFANG78
UNCURATED22
HOKFANG76
Same task evaluation context
MEASURED OUTCOME